Clockwise
A UK roundabout, generated clockwise
This is generated video of a real place. A video model drew it from MapMap's compiled map of Lancing Manor Roundabout; it shows what the model drew, not what happens there, and it forecasts nothing.
GeneratedCosmos3-Nano-Transfer-Auto on MapMap's compiled sceneModelledsixteen cars on the scene pack's lanesLancing Manor RoundaboutSeed 0 of each condition, fixed before any scored clip existed, not picked by looking.
© OpenStreetMap contributors, ODbL 1.0 | Contains OS data © Crown copyright and database right 2026 | Contains Environment Agency information © Environment Agency and/or database right, licensed under the Open Government Licence v3.0
Seven cameras, one drive
The same dusk-and-rain drive from all seven cameras at once, generated in one pass so the model can keep the views consistent. Whether they do agree was not measured. Shown, not scored. From pass 1 (24 Oct), at 832 x 480.
Two registered passes, reported separately
Pass 1 ended without a verdict. Pass 2 was registered before any of it was generated, with denser traffic close to the camera, 720p video, nine counted frames per clip instead of five, and a clearer rule for when a rater may say they cannot tell. The bar is the same. The two passes are never pooled: each has its own outcome.
The honest counter: Pass 2, 26 Oct
Raters disagreed
The two raters agreed poorly (kappa 0.17), so the wrong-side count is shown as a range from 10 to 12 and the third rater's adjudication is marked.
Weather, dusk and rain against clear day: no measurable weather effect. Added after scoring: that rests on 9 wrong-side cars in 520 against 8 in 532 while the raters disagreed, so the comparison had almost no power to find an effect.
Checked by a person
Added after scoring; does not change the outcome.
A MapMap person, blind to the raters' labels, checked the ratings on 27 Oct 2026, one car per screen: correct side, wrong side or cannot tell, then which way it moves over one second. They checked 63 cars in the 18 pass 2 frames taken first: the frames where the final count has a car on the wrong side or driving the wrong way. Of the 19 wrong-side cars in them they called all 19 correct side, and of the 17 wrong-way cars, 16 the right way and 1 could not be told, so none is confirmed. One more wrong-side, wrong-way car (dusk and rain, seed 3, cross-right view, frame 120) and the rest of the pack, including the 10% random sample (87 frames, 341 cars), were not checked. Their labels agreed with the raters' final labels no better than chance (kappa -0.11 for side, -0.08 for direction).
What the check covered: all of pass 1's pack, and of pass 2's pack only the 18 frames taken first (63 cars). The rest of pass 2's pack, 87 frames and 341 cars including its 10% random sample, was not checked by a person.
So this page does not say the model put cars on the wrong side of the road or drove them the wrong way: none of the cars those counts rest on was confirmed by the person. Nor is it a pass. The method set no rule for a human check that disagrees with the raters, so the registered outcome stands as scored, with no verdict, and this is one person's check, not a second pair of raters.
What the person did see were oddities in the model's world: cars drawn on the grass and odd road markings. That is why a "road or car looks wrong" flag was added part-way through the check (it was there for 117 of the 161 cars checked). One car was flagged, in pass 1 (dusk and rain, front view): a small dark car standing on the grass beside a tree. These are findings about the model too, apart from which side of the road it drives on.
Read the counter with this
Added after scoring; does not change the outcome.
- The range of 10 to 12 is the two raters' own wrong-side counts in dusk and rain. This time there were enough cars: 520 in dusk and rain and 532 in clear day could be judged for side (judgeable cars whose side could be told), over the 150 the method needs. The registered rule gives no verdict when kappa is under 0.6, and it is kept.
- The raters gave the same side label to 471 of 498 (dusk, rain), 465 of 513 (clear day), 252 of 265 (dusk, rain, mirrored map) of the cars both could judge, but on the cars that matter they did not match: 47 cars were called wrong side by one rater or both, and they agreed on 2 of them (none of 18 in dusk and rain). Where they differed, one said "correct side" and the other "wrong side" for 42 cars, and "correct side" against "cannot tell" for 43. Every car either rater called wrong side is in the human-check pack.
Inside our boxes, and outside them
Added after scoring; does not change the outcome.
MapMap placed the car boxes in the map control, on the side the map gives traffic: the left, or the right on the mirrored map. A car drawn inside a box is on that side because we put the box there, so the side count mostly measures whether the model drew cars inside our boxes. The failures that matter are cars the model added outside any box, and cars drawn inside a box but facing the wrong way for their lane. They are counted separately here.
Every car the third session counted wrong side or wrong way was checked against the boxes MapMap placed, by projecting each box into the view: for 19 of these 20 cars the nearest box is within 100 pixels (3 to 95 pixels from the car's centre), and every modelled car drives its lane the right way. For 12 of them the nearest box is the same modelled car (car-13), going round the ring the way the map turns, seen in the cross-right and cross-left views; the raters' own notes describe it moving that way, but they placed it in the exit lane beside the ring. So most of these calls are probably the raters reading the lane wrong, not the model drawing a car on the wrong side. The human check took these cars first. The person, blind to the raters' labels, called all 19 wrong-side cars they checked correct side (1 was not checked). None was confirmed, so the wrong-side counts here are not shown as the model's errors.
- Dusk, rain
- 32 judgeable cars the model added outside any box: the third session's count has 1 on the wrong side and 1 the wrong way, none of them confirmed by the person who checked (0 side and 7 direction could not be told).
- 498 judgeable cars drawn inside a box: the third session's count has 8 on the wrong side and 7 the wrong way, none of them confirmed by the person who checked (10 side and 49 direction could not be told).
- Clear day
- 16 judgeable cars the model added outside any box: the third session's count has 0 on the wrong side and 0 the wrong way (0 side and 6 direction could not be told).
- 536 judgeable cars drawn inside a box: the third session's count has 8 on the wrong side and 7 the wrong way, none of them confirmed by the person who checked (20 side and 69 direction could not be told).
- Mirrored map (dusk, rain)
- 17 judgeable cars the model added outside any box: the third session's count has 0 on the wrong side and 0 the wrong way (2 side and 7 direction could not be told).
- 264 judgeable cars drawn inside a box: the third session's count has 3 on the wrong side and 3 the wrong way, none of them confirmed by the person who checked (2 side and 37 direction could not be told).
Every rater was a Claude session. A MapMap person, blind to the raters' labels, checked 63 of the 404 cars in this pass's pack, one car per screen with no rater labels shown, on 27 Oct 2026; what they found is under "Checked by a person" in the counter.
The line at 10% is the pre-registered bar. M: the mirrored map (dusk, rain), where correct means keeping right. Intervals treat each car in a frame as independent; cars in one clip are not, so the per-clip range is given below.
- Dusk, rain
- 8 clips, 216 frames, 530 judgeable cars, 10 side-ambiguous. Per clip, wrong side 1.7% on average (0.0% to 3.1%). Kappa 0.21 side, 0.33 direction.
- Clear day
- 8 clips, 216 frames, 552 judgeable cars, 20 side-ambiguous. Per clip, wrong side 1.5% on average (0.0% to 4.5%). Kappa 0.30 side, 0.35 direction.
- Dusk, rain, mirrored map
- 4 clips, 108 frames, 281 judgeable cars, 4 side-ambiguous. Per clip, wrong side 1.1% on average (0.0% to 2.9%). Kappa 0.17 side, 0.46 direction.
- Decided by the third session
- 408 vehicle rows.
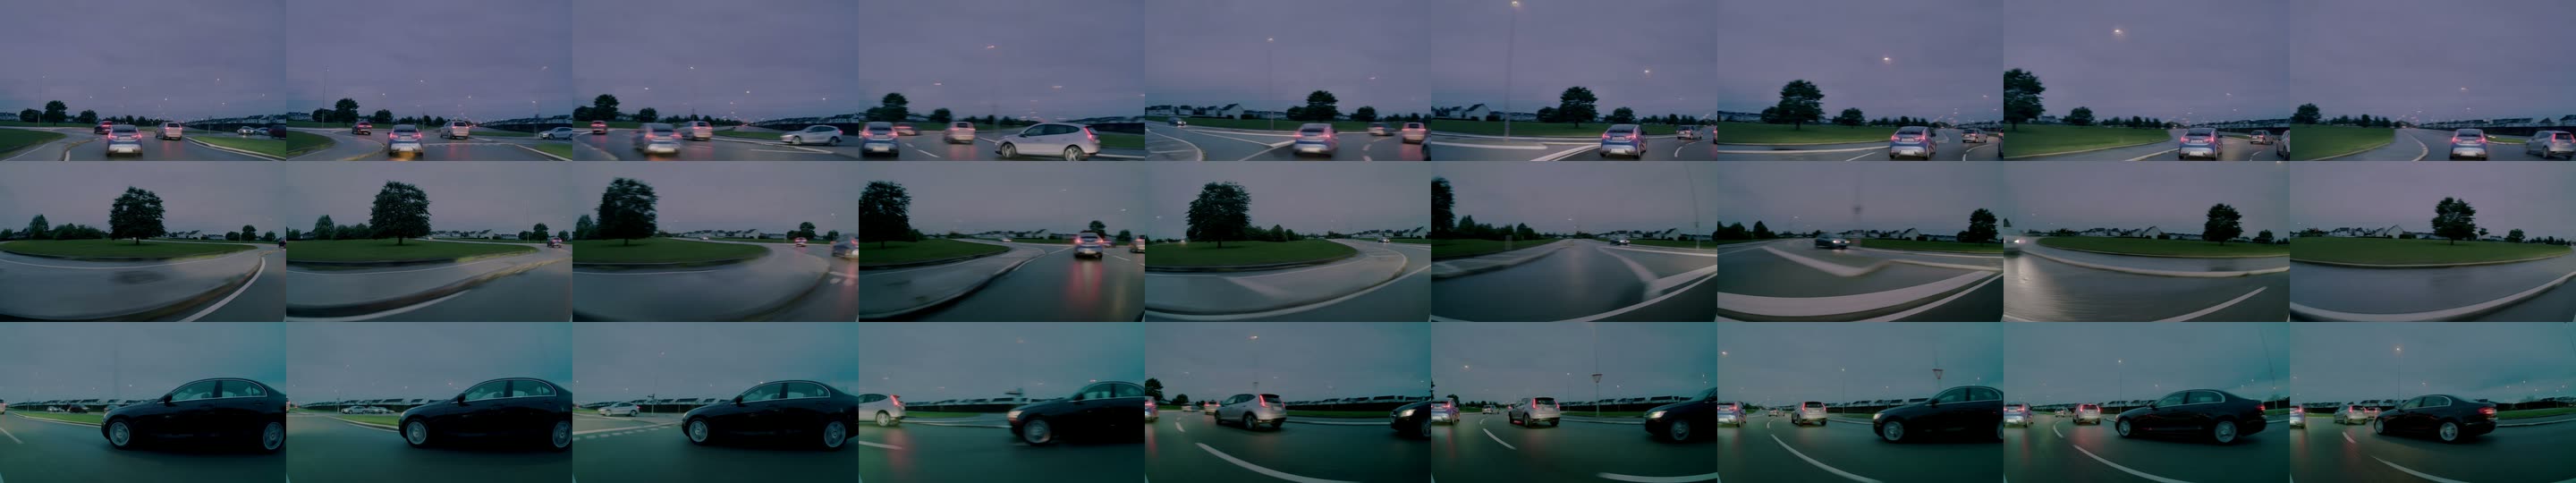
The frames that were counted: Dusk, rain
Seed 0: frames 20, 40, 60, 80, 100, 120, 140, 160 and 180 of the three scored views, as published. Every condition's frames were counted the same way; the full set is archived.
Method, fixed before generation
- What was generated
- Model: NVIDIA Cosmos3-Nano-Transfer-Auto (OpenMDW 1.1), weights from Hugging Face at the revision named in results.json. The prompts describe weather, light, surface and setting only. They never say UK, England, left or clockwise: the map alone carries the side of the road. Four more dusk-and-rain clips whose prompt said "driving on the left in England" were made as an exploratory tier, archived and not scored. Pass 2 makes 1280 x 720 video of the three scored views only (the rear camera was not generated), with the same model, settings and prompts word for word.
- The cameras
- The cameras are a virtual NVIDIA Hyperion 8.1 rig: the calibration bundled with the WSM renderer in NVIDIA/cosmos-framework, attached to a modelled drive through the compiled scene. None of MapMap's own camera footage is used, and the output looks like those cameras, not our rig.
- The traffic and the map
- The traffic is modelled: eight cars follow the compiled lane centrelines of the scene pack at 11.2 m/s, straight across and turning from all four arms, never closer than 7 m. The camera car follows the pack's own modelled drive, west entry to east exit. The map control holds lane lines, kerbs, give-way lines and these car boxes; it has no travel arrows, so the boxes are the only cue for which side to drive on. Pass 2 traffic is modelled too: sixteen cars on the same compiled lane centrelines at the same 11.2 m/s, placed by a seeded search for cars close to the camera car (in the lane beside it, on the ring and oncoming on the east arm), their footprints never overlapping. By the same measure, pass 1's eight cars put about a sixth as many cars within 22 m of the camera at the counted frames. The camera car's drive and the map are unchanged. The mirrored map is the same scene reflected, so the roundabout turns anticlockwise and traffic keeps right. On that map, correct means keeping right.
- Who counted
- Two blinded raters, each a separate series of Claude (Opus) sessions, so the same model with the same rubric and likely to make the same kind of mistake, working from the written rubric with the clip identifiers hidden, label every vehicle in five sampled frames of three views per clip. Agreement is reported as Cohen's kappa; disagreements went to a third session, which decided them, and those rows are marked. Weather is visible in the frames and the mirrored map is recognisable, so neither can be hidden from a rater. Pass 2 raters work the same way over nine sampled frames of three views per clip, at 1280 x 720 with the control frame beside each, from a rubric that sets a fixed order of steps, says which cues decide which way a car faces, and allows "cannot tell" only in three named cases, with ten worked examples. Every rater was a Claude session. A MapMap person, blind to the raters' labels, checked 63 of the 404 cars in this pass's pack, one car per screen with no rater labels shown, on 27 Oct 2026; what they found is under "Checked by a person" in the counter. The sampled frames, control frames, lane diagrams, the rubric and both raters' sheets are archived; anyone may rescore them on request.
- The bar
- Kept to the left means the upper bound of the 95% interval on the wrong-side rate, and on the wrong-direction rate, is at or under 10% in both dusk-and-rain and clear-day clips, with at least 150 judgeable cars in each. The 10% bar is a judgement call, set before generation.
- Registration
- The counting method, the bar and the outcome sentences in the counter were fixed on 24 Oct 2026, before any clip was generated. Notes marked as added after scoring were written once the results were known. The page carries the method file's SHA-256.
60e7cf97a90390fb. Two dated amendments, each committed before the step it covers, record how the scene and the scoring were built: AMENDMENT-1.md, AMENDMENT-2.md. Correction, added after scoring: Amendment 1 is headed 16:00 UTC but was committed at 15:58:12 UTC, and Amendment 2 is headed 16:35 UTC, its item 9 17:05 UTC, but they were committed at 16:22:55 and 17:00:32 UTC. The commit times are the record. The files are left as they are because their hashes are published. Corrections to Amendment 3, added after scoring: it says 60 near car-frames, but the registered traffic.json records 61 (60 was a recount from start offsets rounded to the centimetre). Its "10% sample of the remaining items" was drawn as 10% of all 540 items (54), taken from the 490 not already in the check, as in pass 1. The files are left as they are because their hashes are published. Pass 2 was registered in Amendment 3, committed on 26 Oct 2026 at 11:35 UTC, before any pass 2 GPU existed. It keeps the bar and the outcome sentences, sets its own stop rule, and is never pooled with pass 1. The page carries the amendment's, matrix's and rubric's SHA-256. Amendmentef4a78c2eddaaea5, matrix9590d5b0c6c4d058, rubric50925cd69c89cab4. - Publishing
- Every frame is drawn by the model: no real person, vehicle or number plate appears, so the clips are shown as the model drew them. Three front views are cropped to remove the camera car's bonnet, where the model drew what looks like a car maker's badge; the crop is the same in every frame. Two views are not shown because a car the model drew in them carries what looks like a car maker's badge or grille. Pass 1 used 7.9 GPU hours on rented H100 cards, about USD 32. Pass 2 used 18.1 GPU hours, about USD 72.
- Sources
- Map controls from the Lancing Manor scene pack (OpenStreetMap, OS Open Roads, Environment Agency LiDAR). MapMap is a member of the NVIDIA Inception program.
Map data credits
- © OpenStreetMap contributors, ODbL 1.0
- Contains OS data © Crown copyright and database right 2026
- Contains Environment Agency information © Environment Agency and/or database right, licensed under the Open Government Licence v3.0
- © OpenStreetMap, ODbL 1.0
- © Crown copyright OS
- © Environment Agency, OGL v3.0
What this does not show
- It does not test any driving policy or simulator.
- It says nothing about a camera rig other than Hyperion 8.1, or about MapMap's own rig.
- Beyond the mirrored map, it does not separate the model's habits from the conventions of the map renderer.
- It generates no LiDAR.
- A rate on one roundabout is not a general claim about UK roads.
- Only the road layout and the car boxes come from the map. The buildings, trees, verges and signs are the model's own invention, so the surroundings do not look like Lancing Manor.