Built with open source and open standards
The demos that run on open simulators, open scene formats and open optimisers, with MapMap's maps and routing underneath.
3 demos
The demos
 LiveAutomotive and AV · Physical AI
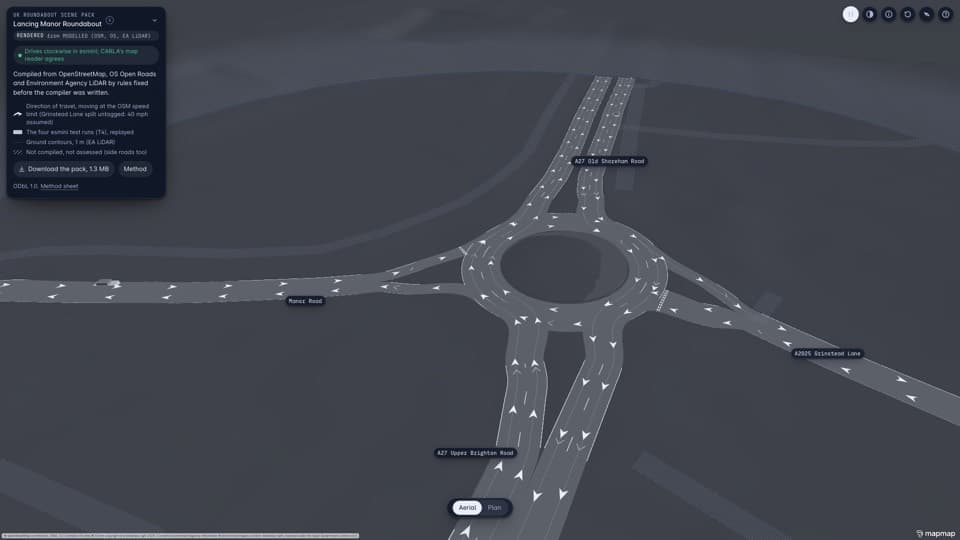
UK roundabout scene pack for AV simulators
- What it is
- Lancing Manor Roundabout compiled from open data (OpenStreetMap, OS Open Roads, Environment Agency LiDAR) into the files AV simulators load: OpenDRIVE, OpenUSD and NVIDIA's RDS-HQ scene format, with clockwise, left-hand lanes. A 1.13 MB pack you can download.
- What it found
- All eight checks set in advance pass: the ring turns clockwise, 75 of 75 lanes are valid, and 4 of 4 test cars complete in esmini (0 of 4 when switched to right-hand traffic, so the check is real). In CARLA one car first took a wrong exit; that was traced to CARLA's own traffic controller, not the pack, and that first fail stays on the page.
- Why it matters
- UK left-hand road geometry in the formats simulation tools read, for AV developers testing in left-hand countries and for simulation teams.
Used- NVIDIA RDS-HQ
- OpenUSD
- ASAM OpenDRIVE
- esmini
- CARLA
- MapMap scene compiler
NVIDIA RDS-HQ · NVIDIA
The pack ships a complete RDS-HQ scene that matches the OpenDRIVE road to within 1 cm.
NVIDIA's driving scene format (roads, lanes, objects and camera poses) that its simulation and world-model tools read.
OpenUSD · Open source and open standards
The same scene as a USD stage.
The open 3D scene format that Omniverse and many other 3D tools read.
ASAM OpenDRIVE · Open source and open standards
The road network, lane by lane, validated by esmini and CARLA's reader.
The open standard for describing road networks, lane by lane, that driving simulators load.
esmini · Open source and open standards
4 of 4 test cars complete clockwise; 0 of 4 when switched to right-hand traffic.
An open-source driving scenario simulator that loads OpenDRIVE roads.
CARLA · Open source and open standards
Map reader agrees; a server run on 24 and 26 October traced a wrong exit to CARLA's controller, not the pack.
The open-source driving simulator widely used in self-driving research.
MapMap scene compiler · MapMap
Open map data to OpenDRIVE, OpenUSD and RDS-HQ.
MapMap's compiler from open map data to the scene files simulators load: OpenDRIVE, OpenUSD and RDS-HQ.
Open the demoUpdated 26 Oct 2026Data: OpenStreetMap, OS Open Roads, Environment Agency LiDAR
 LiveMobility · Smart spaces
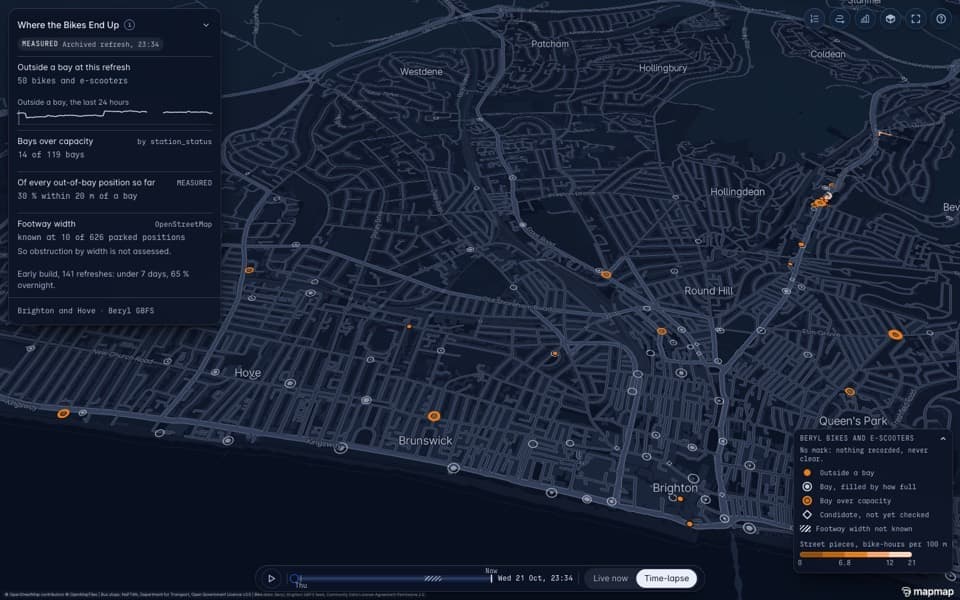
Where the Bikes End Up, Brighton
- What it is
- Brighton's hire bikes and e-scooters, collected every 2 minutes: where they are left outside bays, which bays overflow, and the morning van route that clears them.
- What it found
- At a typical refresh (the median, data from 21 to 26 Oct 2026), 50 of some 880 bikes and e-scooters are outside a bay, and 10 of 119 bays are over capacity. Anything that could point to someone's home is withheld: overnight stays on residential streets, side roads and lone spots on main roads.
- Why it matters
- A real UK fleet job on a real travel-time matrix, for councils that license hire bikes and e-scooters and the operators that rebalance them.
Note: The route is solved by VROOM; NVIDIA cuOpt, run on the same saved instance, found the same plan, but one stop is too small to tell two solvers apart.
Used- NVIDIA cuOpt
- VROOM
- MapMap travel-time matrix
- Pre-registered tests
NVIDIA cuOpt · NVIDIA
Run on the saved instance (same SHA-256) and the same MapMap matrix, on an NVIDIA A40: the same plan as VROOM, 22.5 minutes and 9.2 km, no rule broken. One stop leaves only one route, so it shows the run, not which solver is better.
NVIDIA's GPU route optimiser for fleets and deliveries.
VROOM · Open source and open standards
The morning route, solved through MapMap's hosted optimiser.
An open-source route optimiser. MapMap's hosted optimiser runs it on MapMap's travel-time matrix.
MapMap travel-time matrix · MapMap
Travel times between every bike and bay.
MapMap's many-to-many travel times, the input every route optimiser needs.
Pre-registered tests · MapMap
Definitions, tests and privacy withholding rules committed before any analysis.
MapMap's method: the pass bar is written and hashed before the data is opened, and a failed test stays on the page.
Open the demoUpdated 27 Oct 2026Data: Beryl Brighton GBFS feed (CDLA-Permissive-2.0), OpenStreetMap, NaPTAN (OGL v3.0)
 RenderedLiveInfrastructure · Physical AI · Road safety
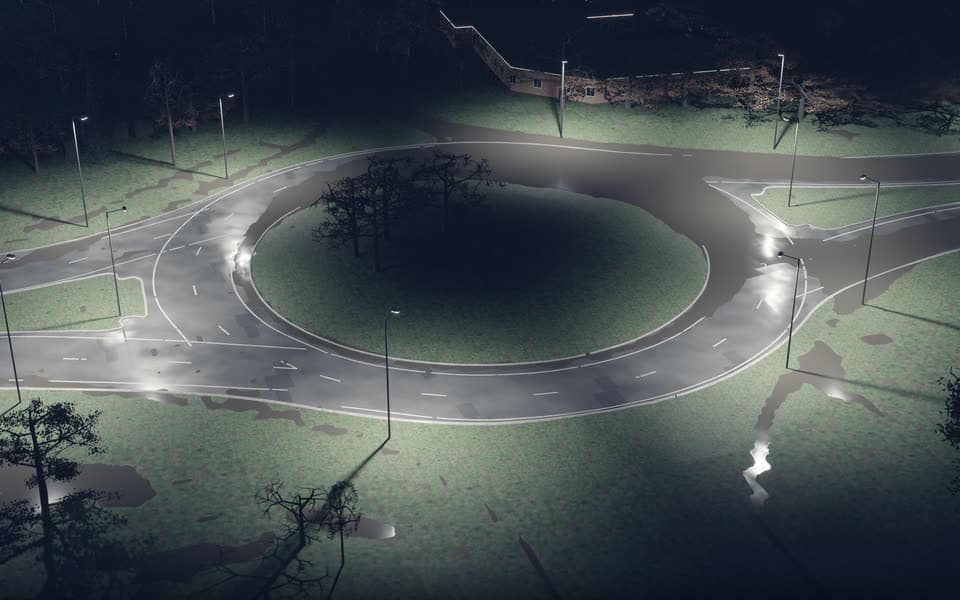
Surface Water on the GPU
- What it is
- The Surface Water Twin's solver, built for NVIDIA GPUs with Warp, run across 76 scenarios (recorded storms, design storms and ground-survey variations, each with and without drainage), then opened and path-traced in NVIDIA Omniverse.
- What it found
- All 76 scenarios finished, and the modelled water opens as an OpenUSD stage in Omniverse, now cut into a 43-second silent film. Our GPU build did not match our own CPU reference within the tolerance we set, so the page gives no speed figures.
- Why it matters
- A real storm on real UK terrain as a scenario set and a rendered scene, for highway drainage and asset teams, flood authorities and teams building physical AI on real ground.
Note: The picture is rendered and the water depths are modelled; the lighting is illustrative.
Used- NVIDIA Warp
- NVIDIA Omniverse
- OpenUSD
- MapMap terrain pipeline
NVIDIA Warp · NVIDIA
The solver's GPU build ran the whole scenario set on one rented NVIDIA RTX 6000 Ada.
NVIDIA's Python framework for writing physics and simulation code that runs on a GPU, or on a CPU.
NVIDIA Omniverse · NVIDIA
Omniverse Kit via Isaac Sim 6.1 opened the stage headless and path-traced the film.
NVIDIA's platform for building and rendering 3D scenes. We open stages headless through Isaac Sim and path-trace them.
OpenUSD · Open source and open standards
The terrain, road and water field exported as a USD stage.
The open 3D scene format that Omniverse and many other 3D tools read.
MapMap terrain pipeline · MapMap
The same Environment Agency ground as the Surface Water Twin.
MapMap's pipeline that turns Environment Agency laser scans into road-level terrain.
Open the demoUpdated 28 Oct 2026Data: Environment Agency LiDAR, Environment Agency rain gauges, OpenStreetMap
The open-source and open-standards technology in these demos
Each model or tool in plain English, and the demos that ran it.
OpenUSD
The open 3D scene format that Omniverse and many other 3D tools read.
Used in: UK roundabout scene pack for AV simulators; Surface Water on the GPU
ASAM OpenDRIVE
The open standard for describing road networks, lane by lane, that driving simulators load.
Used in: UK roundabout scene pack for AV simulators
esmini
An open-source driving scenario simulator that loads OpenDRIVE roads.
Used in: UK roundabout scene pack for AV simulators
CARLA
The open-source driving simulator widely used in self-driving research.
Used in: UK roundabout scene pack for AV simulators
VROOM
An open-source route optimiser. MapMap's hosted optimiser runs it on MapMap's travel-time matrix.
Used in: Where the Bikes End Up, Brighton
Tell us which of these you would like to run with your team.
One email reaches the people who built them. We are happy to walk through any demo, its method and its data.
All demos are built from open data and MapMap's own data. Every number on them comes from a script that can be rerun, and each pass bar was fixed in advance. MapMap is a member of the NVIDIA Inception program.