Built with NVIDIA technology
These are the MapMap demos where we ran NVIDIA models and tools, mostly on real UK roads. MapMap adds the road layer underneath: UK road geometry in the formats NVIDIA's tools read, maps and routing that know the road, and honest measurement. MapMap is a member of the NVIDIA Inception program.
Results
Runs with NVIDIA tools and formats that met the bar set before they ran.
- Open UK roundabout scene pack for AV simulators8 of 8checks pass on a UK roundabout scene packLancing Manor Roundabout compiled from open data into OpenDRIVE, OpenUSD and NVIDIA RDS-HQ, clockwise and left-hand. The RDS-HQ scene matches the OpenDRIVE road to within 1 cm.
- Open Sun Glare Atlas3.8 sto cover every road in Great Britain with NVIDIA WarpThe Sun Glare Atlas skyline step as one Warp kernel: every road in Great Britain (hills only) in 3.8 seconds of GPU kernel time on one rented GPU, giving the CPU's answer on every one of 2.8 million Sussex rays.
- Open Low Bridge Watch0 of 33legs under a low bridge in an NVIDIA cuOpt fleet dayLow Bridge Watch: cuOpt planned 30 drops in Birmingham for 4.5 m lorries on MapMap's height-aware truck matrix. The same day planned on a car matrix sent 2 legs under railway bridges signed 3.9 m and 4.2 m.
NVIDIA models and tools in these demos
NVIDIA RDS-HQ
UK roundabout scene pack for AV simulators; Clockwise: a UK roundabout drawn by NVIDIA's Cosmos world model
NVIDIA Warp
Sun Glare Atlas; Wet roads on England's trunk network; Surface Water Twin, A27 Chichester bypass; Surface Water on the GPU
NVIDIA cuOpt
NVIDIA Omniverse
NVIDIA Earth-2 StormScope
Cosmos3-Nano-Transfer-Auto
Roundabout driving envelope (method check); Clockwise: a UK roundabout drawn by NVIDIA's Cosmos world model
Alpamayo 2 Super
Roundabout driving envelope (method check); Observed driving envelope (UK pilot)
UK road geometry in the formats NVIDIA's tools read
A real UK roundabout, Lancing Manor, compiled from open data into OpenDRIVE, OpenUSD and RDS-HQ, clockwise and left-hand, ready for simulators and world models.
Maps and routing underneath
Routing that knows a lorry's height and redraws around a closure, travel times for fleet optimisers, and road-level terrain from Environment Agency laser scans.
Honest measurement
Every pass bar is written before the data is opened, a failed test stays on the page, and a model's output is scored against real UK roads rather than shown as a showreel.
The map layer your physical-AI city stack is missing
A real UK road graph, routing that reacts, and terrain from laser scans, self-hosted next to the tools you already run.
A detected crash, stall or wrong-way vehicle helps a city most when the road network reacts to it.
MapMap is that layer: routing that knows a lorry's height and redraws around a closure, travel-time matrices for fleet optimisers, and road-level terrain from Environment Agency laser scans, on our servers or on yours. Three city demos show it on real UK roads.
Where the Bikes End Up, Brighton
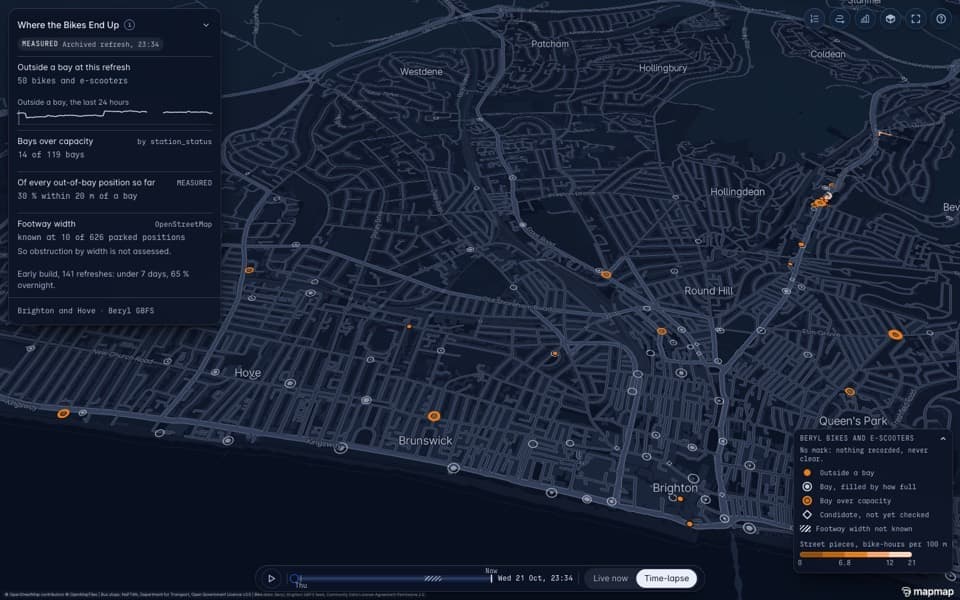
Brighton's hire bikes and e-scooters, collected every 2 minutes: which bays overflow, what is left outside a bay, and the morning van route that clears them, solved on MapMap's travel-time matrix.
At a typical refresh (21 to 26 Oct 2026), 50 of some 880 bikes and e-scooters are outside a bay and 10 of 119 bays are over capacity.
Low Bridge Watch
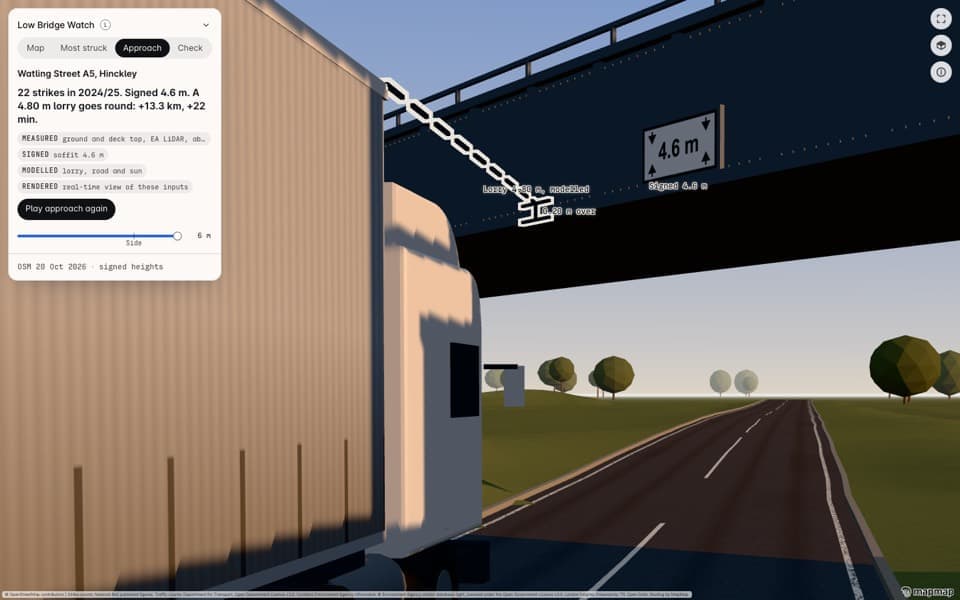
4,304 low bridges on British roads, and the height-aware lorry route that goes round a bridge the car route goes under.
Our bridge-strike ranking puts 11 of the 14 most-struck bridges on Network Rail's published list in its top 5%.
Surface Water Twin, A27 Chichester bypass
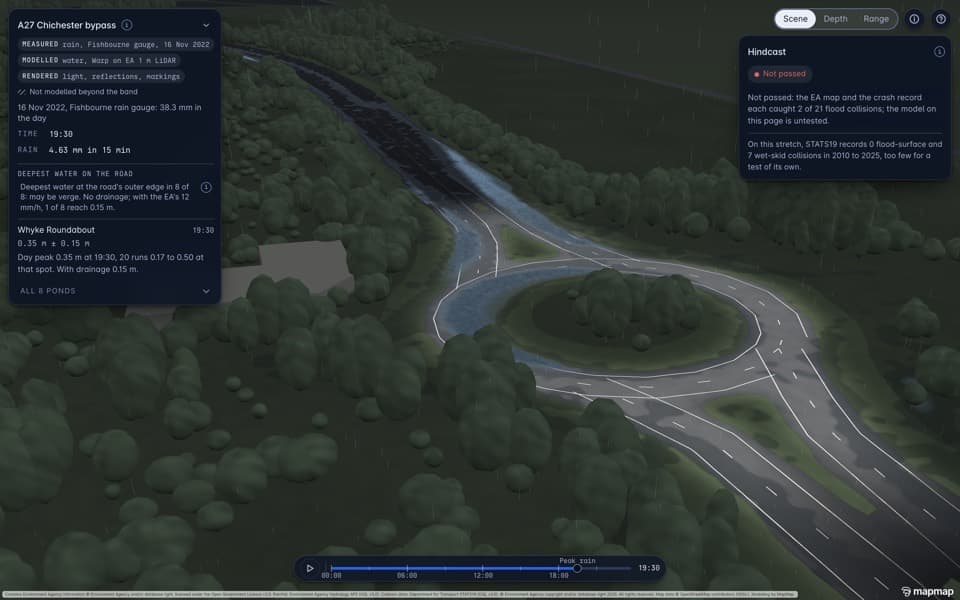
A real storm from an Environment Agency rain gauge, rained onto a laser scan of the A27 Chichester bypass by our shallow-water solver written in NVIDIA Warp, to show where water gathers on the carriageway.
Whyke Roundabout pools to about 0.35 m in the model (0.17 to 0.50 m across 20 runs). Modelled, not measured.
11 demos
The demos
 LiveAutomotive and AV · Physical AI
UK roundabout scene pack for AV simulators
- What it is
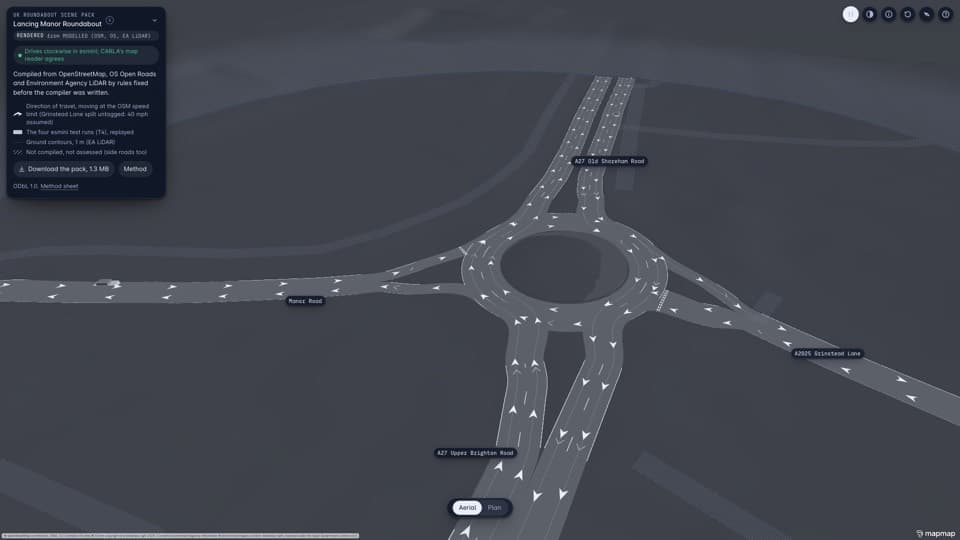
- Lancing Manor Roundabout compiled from open data (OpenStreetMap, OS Open Roads, Environment Agency LiDAR) into the files AV simulators load: OpenDRIVE, OpenUSD and NVIDIA's RDS-HQ scene format, with clockwise, left-hand lanes. A 1.13 MB pack you can download.
- What it found
- All eight checks set in advance pass: the ring turns clockwise, 75 of 75 lanes are valid, and 4 of 4 test cars complete in esmini (0 of 4 when switched to right-hand traffic, so the check is real). In CARLA one car first took a wrong exit; that was traced to CARLA's own traffic controller, not the pack, and that first fail stays on the page.
- Why it matters
- UK left-hand road geometry in the formats simulation tools read, for AV developers testing in left-hand countries and for simulation teams.
Used- NVIDIA RDS-HQ
- OpenUSD
- ASAM OpenDRIVE
- esmini
- CARLA
- MapMap scene compiler
NVIDIA RDS-HQ · NVIDIA
The pack ships a complete RDS-HQ scene that matches the OpenDRIVE road to within 1 cm.
NVIDIA's driving scene format (roads, lanes, objects and camera poses) that its simulation and world-model tools read.
OpenUSD · Open source and open standards
The same scene as a USD stage.
The open 3D scene format that Omniverse and many other 3D tools read.
ASAM OpenDRIVE · Open source and open standards
The road network, lane by lane, validated by esmini and CARLA's reader.
The open standard for describing road networks, lane by lane, that driving simulators load.
esmini · Open source and open standards
4 of 4 test cars complete clockwise; 0 of 4 when switched to right-hand traffic.
An open-source driving scenario simulator that loads OpenDRIVE roads.
CARLA · Open source and open standards
Map reader agrees; a server run on 24 and 26 October traced a wrong exit to CARLA's controller, not the pack.
The open-source driving simulator widely used in self-driving research.
MapMap scene compiler · MapMap
Open map data to OpenDRIVE, OpenUSD and RDS-HQ.
MapMap's compiler from open map data to the scene files simulators load: OpenDRIVE, OpenUSD and RDS-HQ.
Open the demoUpdated 26 Oct 2026Data: OpenStreetMap, OS Open Roads, Environment Agency LiDAR
 LiveRoad safety · Physical AI
Sun Glare Atlas
- What it is
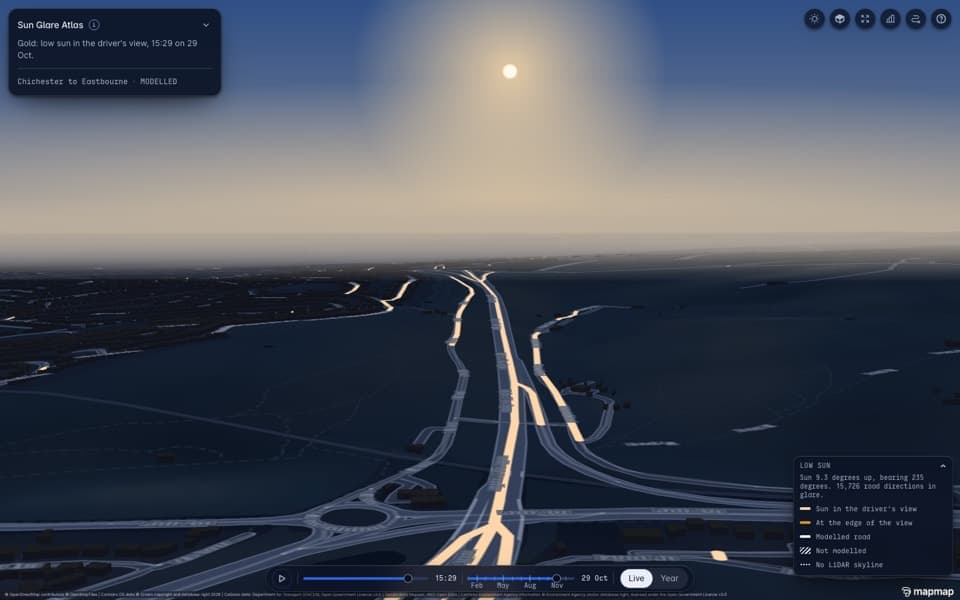
- A map of Sussex roads with a time slider: roads glow gold at the exact minutes drivers stare into a low sun, worked out from where the sun really is and whether hills block it.
- What it found
- Across Britain, driving into a low sun goes with about 7.5% more crashes than driving away from it. Sun angle alone cannot pick out single danger spots, and the page says so.
- Why it matters
- Physically based light on a real road network, for councils and highway authorities, fleet operators, insurers and road safety charities. A timely story around each clock change.
Note: Modelled glare assumes a clear sky; the into-sun figure is not adjusted for season (adjusting shrinks it to about 3 to 5%).
Used- NVIDIA Warp
- NVIDIA Omniverse
- MapMap terrain pipeline
- Pre-registered tests
NVIDIA Warp · NVIDIA
The skyline step as one Warp kernel gives the CPU's answer on every one of 2.8 million Sussex rays, then covered every road in Great Britain (hills only) in 3.8 seconds of GPU kernel time on one rented GPU.
NVIDIA's Python framework for writing physics and simulation code that runs on a GPU, or on a CPU.
NVIDIA Omniverse · NVIDIA
One bend the atlas flags, on the A259 near Bognor Regis, path-traced from the driver's eye at its modelled glare minute. The picture is rendered and the minute modelled.
NVIDIA's platform for building and rendering 3D scenes. We open stages headless through Isaac Sim and path-trace them.
MapMap terrain pipeline · MapMap
The skyline each road sees, cut from Environment Agency LiDAR.
MapMap's pipeline that turns Environment Agency laser scans into road-level terrain.
Pre-registered tests · MapMap
The into-sun test and its rain placebo were fixed before the collision data was opened.
MapMap's method: the pass bar is written and hashed before the data is opened, and a failed test stays on the page.
Open the demoUpdated 27 Oct 2026Data: OS Open Roads, Environment Agency LiDAR, STATS19 collision records, OS Terrain 50
 LiveRoad safety · Mobility · Infrastructure
Low Bridge Watch
- What it is
- 4,304 low bridges on British roads, Network Rail's most-struck bridges, and a check that shows the car route going under a bridge and the height-aware lorry route going round.
- What it found
- Our bridge-strike ranking puts 11 of the 14 most-struck bridges on Network Rail's published list in its top 5%. At the A5 bridge at Hinckley, struck 22 times in 2024/25, a 4.80 m lorry has to go round: 13.3 km and 22 minutes more. Truck routing kept the lorry from passing under all 19 bridges the car route passed under. Fleet day: NVIDIA cuOpt planned 30 drops in Birmingham for 4.5 m lorries with none of its 33 legs under a bridge signed lower in OpenStreetMap (the heights the router reads); the same day planned on a car matrix sent 2 legs under railway bridges signed 3.9 m and 4.2 m.
- Why it matters
- What a height-aware routing layer adds, for railway bridge owners, hauliers, fleet insurers, councils, and van and minibus drivers.
Note: Advisory only, from map data that can be wrong or out of date.
Used- NVIDIA cuOpt
- MapMap routing
- Pre-registered tests
NVIDIA cuOpt · NVIDIA
A pre-registered fleet day: cuOpt 26.10 on an NVIDIA A40 planned 30 drops for 4.5 m lorries on MapMap's height-aware truck matrix, and none of its 33 legs went under a bridge signed lower in OpenStreetMap (the same heights the router reads). VROOM found the same plan.
NVIDIA's GPU route optimiser for fleets and deliveries.
MapMap routing · MapMap
Car and truck routes through the same bridges; the truck route respects the signed height.
MapMap's routing engine, including truck routing that respects vehicle height, and live closures that redraw routes.
Pre-registered tests · MapMap
The strike-ranking tests were pre-registered against Network Rail's published lists.
MapMap's method: the pass bar is written and hashed before the data is opened, and a failed test stays on the page.
Open the demoUpdated 27 Oct 2026Data: OpenStreetMap, Network Rail bridge strike lists, OS Open Roads
 LiveMobility · Smart spaces
Where the Bikes End Up, Brighton
- What it is
- Brighton's hire bikes and e-scooters, collected every 2 minutes: where they are left outside bays, which bays overflow, and the morning van route that clears them.
- What it found
- At a typical refresh (the median, data from 21 to 26 Oct 2026), 50 of some 880 bikes and e-scooters are outside a bay, and 10 of 119 bays are over capacity. Anything that could point to someone's home is withheld: overnight stays on residential streets, side roads and lone spots on main roads.
- Why it matters
- A real UK fleet job on a real travel-time matrix, for councils that license hire bikes and e-scooters and the operators that rebalance them.
Note: The route is solved by VROOM; NVIDIA cuOpt, run on the same saved instance, found the same plan, but one stop is too small to tell two solvers apart.
Used- NVIDIA cuOpt
- VROOM
- MapMap travel-time matrix
- Pre-registered tests
NVIDIA cuOpt · NVIDIA
Run on the saved instance (same SHA-256) and the same MapMap matrix, on an NVIDIA A40: the same plan as VROOM, 22.5 minutes and 9.2 km, no rule broken. One stop leaves only one route, so it shows the run, not which solver is better.
NVIDIA's GPU route optimiser for fleets and deliveries.
VROOM · Open source and open standards
The morning route, solved through MapMap's hosted optimiser.
An open-source route optimiser. MapMap's hosted optimiser runs it on MapMap's travel-time matrix.
MapMap travel-time matrix · MapMap
Travel times between every bike and bay.
MapMap's many-to-many travel times, the input every route optimiser needs.
Pre-registered tests · MapMap
Definitions, tests and privacy withholding rules committed before any analysis.
MapMap's method: the pass bar is written and hashed before the data is opened, and a failed test stays on the page.
Open the demoUpdated 27 Oct 2026Data: Beryl Brighton GBFS feed (CDLA-Permissive-2.0), OpenStreetMap, NaPTAN (OGL v3.0)
 RenderedLiveInfrastructure · Physical AI · Road safety
Surface Water on the GPU
- What it is
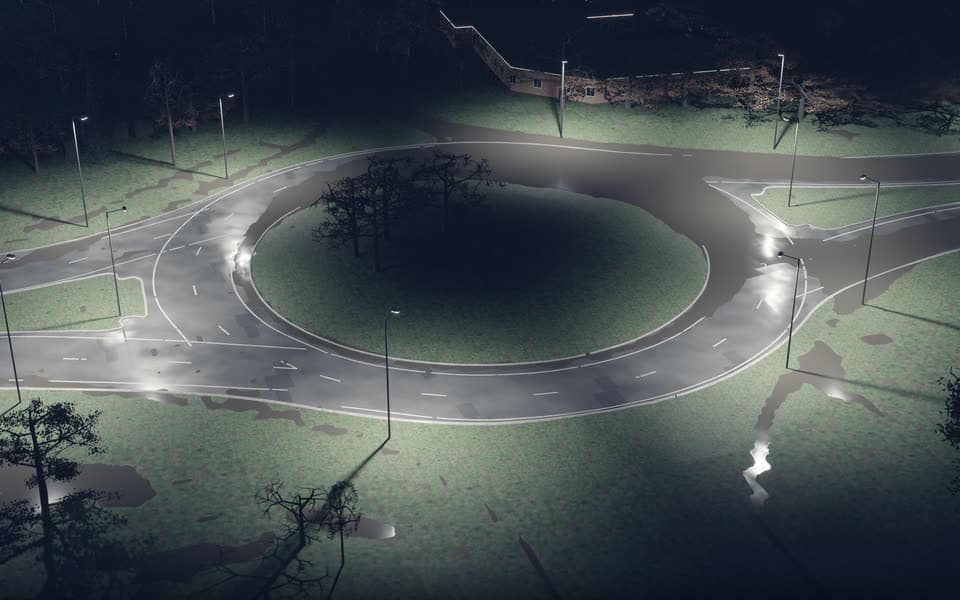
- The Surface Water Twin's solver, built for NVIDIA GPUs with Warp, run across 76 scenarios (recorded storms, design storms and ground-survey variations, each with and without drainage), then opened and path-traced in NVIDIA Omniverse.
- What it found
- All 76 scenarios finished, and the modelled water opens as an OpenUSD stage in Omniverse, now cut into a 43-second silent film. Our GPU build did not match our own CPU reference within the tolerance we set, so the page gives no speed figures.
- Why it matters
- A real storm on real UK terrain as a scenario set and a rendered scene, for highway drainage and asset teams, flood authorities and teams building physical AI on real ground.
Note: The picture is rendered and the water depths are modelled; the lighting is illustrative.
Used- NVIDIA Warp
- NVIDIA Omniverse
- OpenUSD
- MapMap terrain pipeline
NVIDIA Warp · NVIDIA
The solver's GPU build ran the whole scenario set on one rented NVIDIA RTX 6000 Ada.
NVIDIA's Python framework for writing physics and simulation code that runs on a GPU, or on a CPU.
NVIDIA Omniverse · NVIDIA
Omniverse Kit via Isaac Sim 6.1 opened the stage headless and path-traced the film.
NVIDIA's platform for building and rendering 3D scenes. We open stages headless through Isaac Sim and path-trace them.
OpenUSD · Open source and open standards
The terrain, road and water field exported as a USD stage.
The open 3D scene format that Omniverse and many other 3D tools read.
MapMap terrain pipeline · MapMap
The same Environment Agency ground as the Surface Water Twin.
MapMap's pipeline that turns Environment Agency laser scans into road-level terrain.
Open the demoUpdated 28 Oct 2026Data: Environment Agency LiDAR, Environment Agency rain gauges, OpenStreetMap
 LiveRoad safety · Infrastructure · Physical AI
Surface Water Twin, A27 Chichester bypass
- What it is
- A real storm (16 November 2022, from an Environment Agency rain gauge) rained onto a laser scan of the A27 Chichester bypass, with a shallow-water simulation showing where water gathers on the carriageway.
- What it found
- Whyke Roundabout pools to about 0.35 m in the model (0.17 to 0.50 m across 20 runs that vary the ground survey); with a drainage allowance only 1 of 8 ponds reaches 0.15 m. The crash check did not pass, and the page says so: the Environment Agency's flood map caught 2 of 21 flood-related crashes in Sussex, the same as simply using where crashes had happened before. The water model itself can't be checked this way, as no flood crashes have been recorded on this stretch since 2010.
- Why it matters
- Our own shallow-water solver, written in NVIDIA Warp, on real UK terrain with a real storm, for highway drainage and asset teams, flood authorities and insurers.
Note: Modelled, not measured: the deepest water sits at the road's outer edge, which may be verge, and no gauge on the carriageway confirms the depths.
Used- NVIDIA Warp
- MapMap terrain pipeline
- Pre-registered tests
NVIDIA Warp · NVIDIA
The shallow-water solver is written in Warp 1.18 and ran on a CPU for this page.
NVIDIA's Python framework for writing physics and simulation code that runs on a GPU, or on a CPU.
MapMap terrain pipeline · MapMap
Environment Agency 1 m LiDAR of the bypass as the ground.
MapMap's pipeline that turns Environment Agency laser scans into road-level terrain.
Pre-registered tests · MapMap
Solver checks and the crash-record test were fixed in advance; the crash-record miss is on the page.
MapMap's method: the pass bar is written and hashed before the data is opened, and a failed test stays on the page.
Open the demoUpdated 23 Oct 2026Data: Environment Agency LiDAR, Environment Agency rain gauge (Fishbourne), OpenStreetMap, STATS19 collision records
 LiveMobility · Road safety
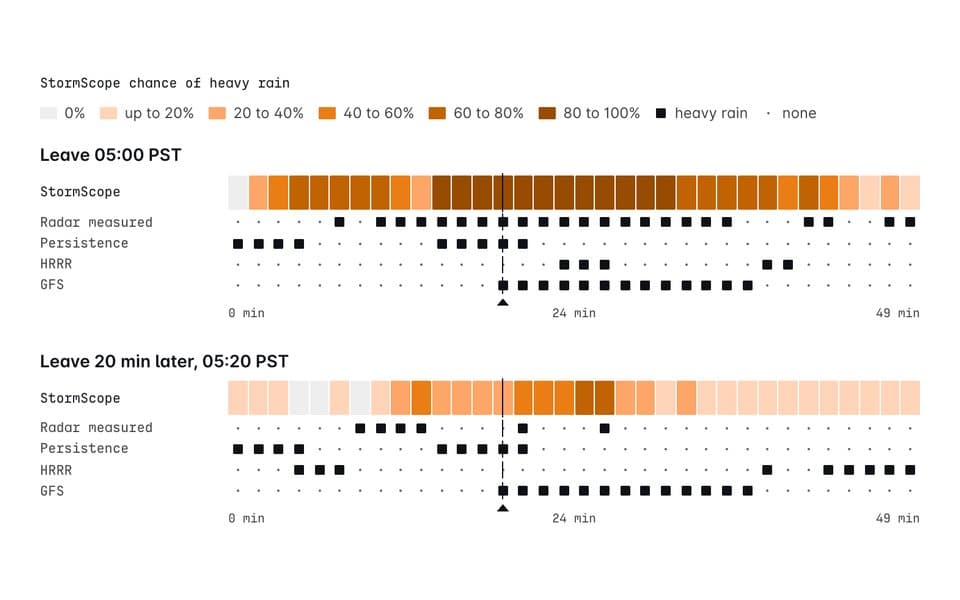
Rain on your route, next 3 hours (San Jose)
- What it is
- NVIDIA's Earth-2 StormScope gives a chance of heavy rain every 10 minutes for three hours. We read it on each 3 km stretch of 12 MapMap routes out of San Jose, at the minute a car reaches it, with a leave-20-minutes-later comparison.
- What it found
- Pre-registered test met: across 624 forecasts on 13 rain days (January to March 2026), scored against radar, its chance of heavy rain beat radar persistence beyond an hour and GFS at every lead. Weak points on the page: small chances run low (9% forecast, 28% observed), and as a yes or no at 50% it flags only 20% of wet trips.
- Why it matters
- An open NVIDIA nowcasting model tied to real routes and scored in public, for fleet operators, transport authorities and anyone weighing an AI weather forecast for the road.
Note: Advisory only, never a warning service. Radar reflectivity stands in for rain on the road, and it is one winter around one city.
Used- NVIDIA Earth-2 StormScope
- MapMap routing
- Pre-registered tests
NVIDIA Earth-2 StormScope · NVIDIA
StormScope-GOES-MRMS (Flash) ran 624 forecasts of 16 members on rented NVIDIA H100 GPUs, every half hour on the 13 qualifying days, scored against NOAA radar.
NVIDIA's AI weather nowcasting model: from satellite and radar, it forecasts the next three hours of rain radar over the US every 10 minutes, as a set of 16 possible outcomes.
MapMap routing · MapMap
The 12 routes, and the minute a car reaches each 3 km stretch.
MapMap's routing engine, including truck routing that respects vehicle height, and live closures that redraw routes.
Pre-registered tests · MapMap
The pass rule, the cases and the example-trip rule were committed before any forecast; the weak points are on the page.
MapMap's method: the pass bar is written and hashed before the data is opened, and a failed test stays on the page.
Open the demoUpdated 31 Oct 2026Data: NOAA MRMS radar, NOAA GOES-19 satellite, NOAA HRRR, NOAA GFS, OpenStreetMap
 Generatednot a photographLiveAutomotive and AV · Physical AI
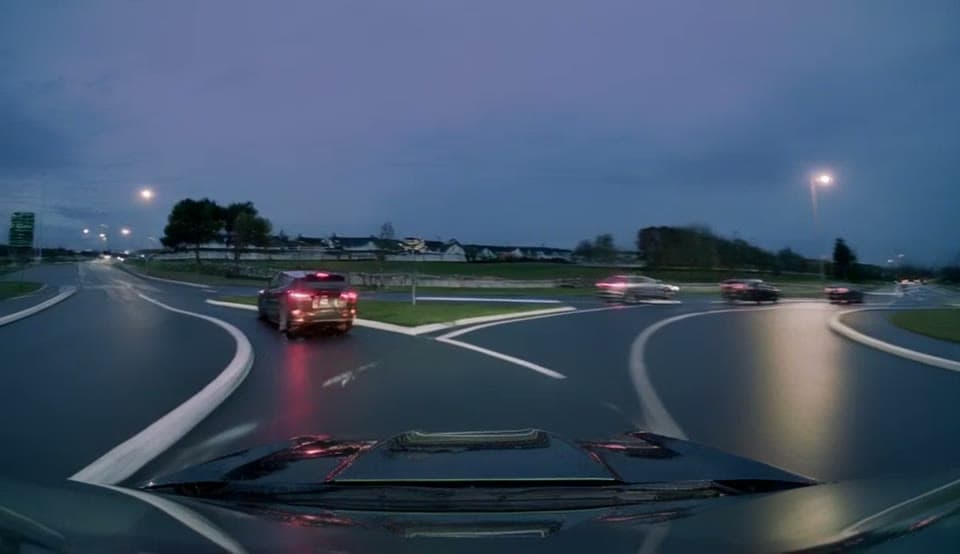
Clockwise: a UK roundabout drawn by NVIDIA's Cosmos world model
- What it is
- NVIDIA's Cosmos3-Nano-Transfer-Auto paints synchronised dashcam views of Lancing Manor Roundabout from MapMap's compiled scene, in rain at dusk and in clear day, and on a mirrored map as a check. Every frame is labelled GENERATED, and a count fixed before generation reports how often it put cars on the wrong side.
- What it found
- Two pre-registered passes, both ending with no verdict. Two Claude sessions rated the cars in sampled frames and agreed too poorly for a verdict; a third session settled the cars they disagreed on, which gives the count of cars on the wrong side. A MapMap person then checked the cars blind, without the raters' labels: all of pass 1's sample, and 18 of the 19 pass 2 frames with cars the count puts on the wrong side. Of the 20 such cars they checked, they confirmed none. What they did see were cars drawn on the grass and odd road markings, oddities of the model's world, not wrong-side driving.
- Why it matters
- A newly released NVIDIA world model run on a UK left-hand map in the camera layout it was trained on, with an honest count rather than a showreel, for AV and simulation teams that need UK synthetic footage and anyone evaluating world models.
Note: MapMap placed the car boxes, so the count mostly measures whether the model drew cars inside them; the surroundings are the model's own invention, not Lancing Manor. The person's check covered pass 1's whole sample and, in pass 2, the 18 frames taken first: 63 of the 404 cars in its check pack. Every frame is generated, so no real people or vehicles appear. The page shows 25 generated clips: 18 from pass 1, including one drive from all seven cameras, and 7 from pass 2. Front views where the model drew a car maker's badge on the camera car's bonnet are cropped.
Used- Cosmos3-Nano-Transfer-Auto
- NVIDIA RDS-HQ
- MapMap scene compiler
Cosmos3-Nano-Transfer-Auto · NVIDIA
Run on rented NVIDIA H100 GPUs: 26 clips in pass 1 and 20 at 720p in pass 2, each drawn from the scene's road and car layout and a one-line description per camera.
NVIDIA's world model that paints realistic multi-camera driving footage from a labelled scene.
NVIDIA RDS-HQ · NVIDIA
The layout videos the model draws from are rendered from the pack's RDS-HQ scene with NVIDIA's own renderer.
NVIDIA's driving scene format (roads, lanes, objects and camera poses) that its simulation and world-model tools read.
MapMap scene compiler · MapMap
The roundabout scene, its modelled cars (eight in pass 1, sixteen in pass 2) and the mirrored map.
MapMap's compiler from open map data to the scene files simulators load: OpenDRIVE, OpenUSD and RDS-HQ.
Open the demoUpdated 29 Oct 2026Data: OpenStreetMap, OS Open Roads, Environment Agency LiDAR
 LiveAutomotive and AV · Road safety · Physical AI
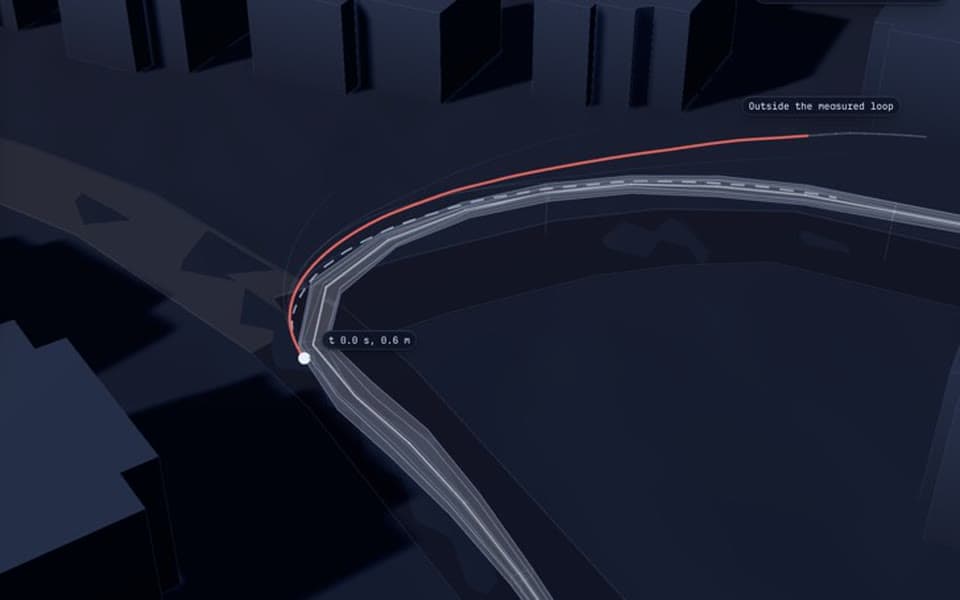
Observed driving envelope (UK pilot)
- What it is
- One driver's twelve passes round a Worthing loop become a band of how a human really drove it, and the paths from NVIDIA's Alpamayo driving model are measured against that band in 3D.
- What it found
- A pilot with one driver and twelve passes, which the calibration test set in advance found too few to calibrate. Alpamayo's paths leave the driver's band 45 percentage points more often than the driver's own passes do. Mirroring the scene to right-hand traffic made no difference, so this test finds no sign that the gap comes from UK left-hand traffic.
- Why it matters
- A ruler for driving models on a real UK street, to rerun on every model release rather than a critique, for UK regulators, transport authorities and AV operators.
Note: Passes over the 30 mph limit are drawn as over the limit, never as careful driving. The counts of wording in the model's reasoning come from text rules, not a person's reading.
Used- Alpamayo 2 Super
- Pre-registered tests
Alpamayo 2 Super · NVIDIA
Alpamayo 2 Super's paths on 20 samples (two navigation modes, six trajectories each), plus a mirrored-world control run.
NVIDIA's open driving model: given camera frames, it proposes where the car should go next.
Pre-registered tests · MapMap
The band, the out-of-band measure and the camera-heading sweep were fixed before scoring.
MapMap's method: the pass bar is written and hashed before the data is opened, and a failed test stays on the page.
Open the demoUpdated 24 Oct 2026Data: MapMap rig drives (twelve passes), OS Open Roads, Environment Agency LiDAR
 LiveAutomotive and AV · Road safety
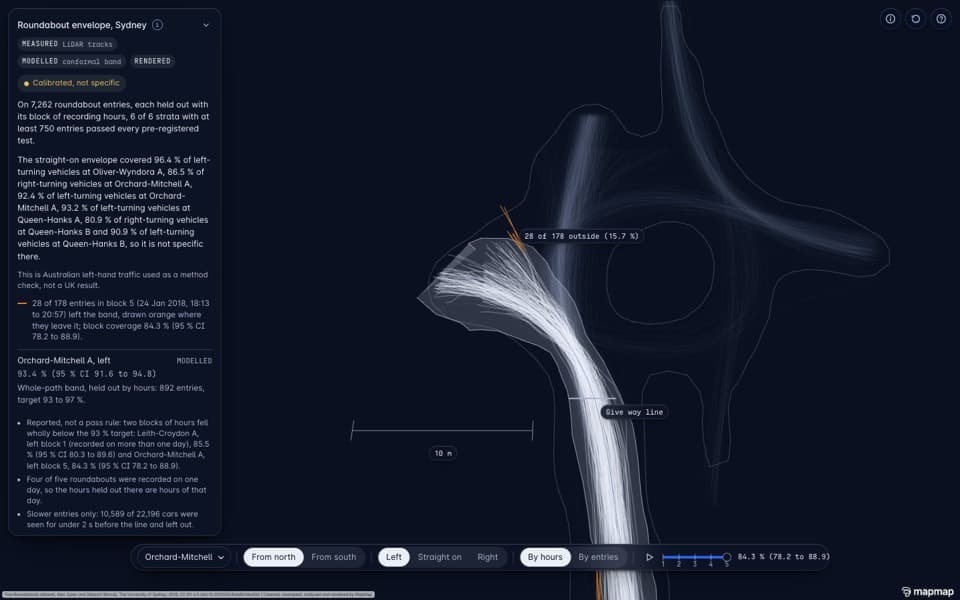
Roundabout driving envelope (method check)
- What it is
- Thousands of real cars entering roundabouts from an open Australian dataset (left-hand traffic, like the UK), turned into a band of normal driving and tested on recording hours it had not seen.
- What it found
- The band held its 93 to 97% target on all six busy entrances, but it cannot tell straight-on from turning cars, and a band from one roundabout did not carry to others (1 of 5). Both failures are shown. On generated clips of a Sussex roundabout, Alpamayo 2 Super's paths sat outside the band at 66% of points, against under 1% for real drivers.
- Why it matters
- The measuring tool an AV safety case needs, done in public on left-hand traffic, for UK regulators, AV companies applying for UK permits and academic reviewers.
Note: Australian data, used as a method check; never presented as a UK result. CC BY 4.0, credited to the dataset authors.
Used- Cosmos3-Nano-Transfer-Auto
- Alpamayo 2 Super
- Pre-registered tests
Cosmos3-Nano-Transfer-Auto · NVIDIA
The input: Cosmos3-Nano-Transfer-Auto clips of Lancing Manor generated on 24 Oct 2026, reused here with no new generation.
NVIDIA's world model that paints realistic multi-camera driving footage from a labelled scene.
Alpamayo 2 Super · NVIDIA
Run on 27 Oct 2026 on generated clips of Lancing Manor Roundabout (not real driving), scored against the band's width with a mirrored-world control, both fixed in advance: Alpamayo 2 Super's paths were outside the band at 66% of points, against under 1% for real drivers; the mirrored world made no clear difference.
NVIDIA's open driving model: given camera frames, it proposes where the car should go next.
Pre-registered tests · MapMap
Calibration target and held-out hours fixed in advance; both failures reported.
MapMap's method: the pass bar is written and hashed before the data is opened, and a failed test stays on the page.
Open the demoUpdated 27 Oct 2026Data: University of Sydney roundabout dataset (CC BY 4.0)
 LiveRoad safety · Infrastructure
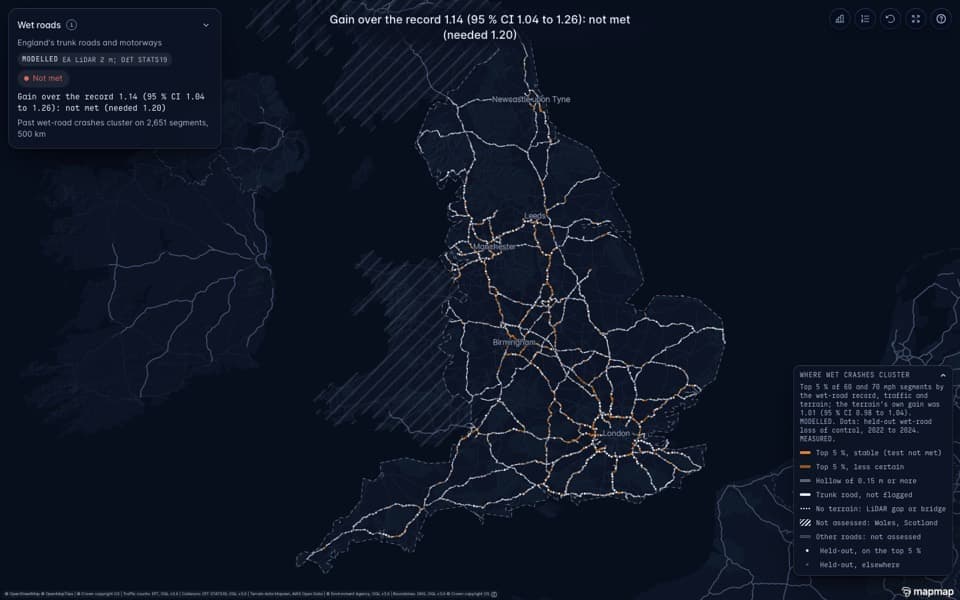
Wet roads on England's trunk network
- What it is
- England's motorways and trunk roads screened for dips from laser terrain scans (4,779 segments have a hollow deeper than the scans' 15 cm error), then a test of whether wet-weather crashes cluster there, with the pass bar fixed before it ran.
- What it found
- Not met: terrain adds 14% over the crash record alone, short of the 20% bar set in advance. The stretches it flags are where past wet-road crashes cluster, mostly busy motorways, not the dips.
- Why it matters
- The honest national screening step before anyone claims to know where wet roads are dangerous, for highway operators' drainage and safety teams and for insurers.
Used- NVIDIA Warp
- MapMap terrain pipeline
- Pre-registered tests
NVIDIA Warp · NVIDIA
The national crash test was not met; as a follow-on, our Warp shallow-water solver ran 330 times on one rented NVIDIA RTX 6000 Ada at 15 sites chosen by a rule fixed in advance (the strongest dips where wet-road crashes cluster), with a synthetic storm. With only the EA drainage allowance and no gullies, water stands at all 15 in the model; GPU and CPU agree at 11 of 15.
NVIDIA's Python framework for writing physics and simulation code that runs on a GPU, or on a CPU.
MapMap terrain pipeline · MapMap
Dips and flat spots along the whole trunk network from Environment Agency 2 m LiDAR.
MapMap's pipeline that turns Environment Agency laser scans into road-level terrain.
Pre-registered tests · MapMap
The 20% bar (a gain of 1.2) was set before the model saw the held-out crashes, and the miss is on the page.
MapMap's method: the pass bar is written and hashed before the data is opened, and a failed test stays on the page.
Open the demoUpdated 27 Oct 2026Data: Environment Agency LiDAR, OS Open Roads, STATS19 collision records
The NVIDIA technology in these demos
Each model or tool in plain English, and the demos that ran it.
Cosmos3-Nano-Transfer-Auto
NVIDIA's world model that paints realistic multi-camera driving footage from a labelled scene.
Used in: Roundabout driving envelope (method check); Clockwise: a UK roundabout drawn by NVIDIA's Cosmos world model
Alpamayo 2 Super
NVIDIA's open driving model: given camera frames, it proposes where the car should go next.
Used in: Roundabout driving envelope (method check); Observed driving envelope (UK pilot)
NVIDIA Warp
NVIDIA's Python framework for writing physics and simulation code that runs on a GPU, or on a CPU.
Used in: Sun Glare Atlas; Wet roads on England's trunk network; Surface Water Twin, A27 Chichester bypass; Surface Water on the GPU
NVIDIA Omniverse
NVIDIA's platform for building and rendering 3D scenes. We open stages headless through Isaac Sim and path-trace them.
Used in: Sun Glare Atlas; Surface Water on the GPU
NVIDIA cuOpt
NVIDIA's GPU route optimiser for fleets and deliveries.
Used in: Low Bridge Watch; Where the Bikes End Up, Brighton
NVIDIA RDS-HQ
NVIDIA's driving scene format (roads, lanes, objects and camera poses) that its simulation and world-model tools read.
Used in: UK roundabout scene pack for AV simulators; Clockwise: a UK roundabout drawn by NVIDIA's Cosmos world model
NVIDIA Earth-2 StormScope
NVIDIA's AI weather nowcasting model: from satellite and radar, it forecasts the next three hours of rain radar over the US every 10 minutes, as a set of 16 possible outcomes.
Used in: Rain on your route, next 3 hours (San Jose)
What MapMap offers teams building with NVIDIA tools
Each of these has shipped, and each has a live demo on this page.
UK left-hand roundabout scene packs
Scene packs compiled from open UK map data into OpenDRIVE, OpenUSD and NVIDIA RDS-HQ, with clockwise, left-hand lanes, for simulator and world-model evaluation. Lancing Manor Roundabout is ready to download today.
Open UK roundabout scene pack for AV simulatorsTruck-aware routing and travel-time matrices
Routing that respects a lorry's height, and the many-to-many travel times a fleet optimiser such as NVIDIA cuOpt solves on. On our truck matrix, cuOpt planned a fleet day with no leg under a bridge signed lower than the lorry.
Open Low Bridge WatchRoad-level hazard simulation with NVIDIA Warp
The sun-glare skyline for every road in Great Britain, and modelled surface water on Environment Agency laser terrain, written in NVIDIA Warp and run on a GPU.
Open Sun Glare Atlas
Meet us at Smart City Expo World Congress, Barcelona, Tuesday 3 November.
Email us to find a time: hello@mapmap.ai
All demos are built from open data and MapMap's own data. Every number on them comes from a script that can be rerun, and each pass bar was fixed in advance.
MapMap is a member of the NVIDIA Inception program. The demos on this page are our own work, run on NVIDIA software and models available to developers; NVIDIA and the other owners named have not reviewed or approved them, and the page implies no partnership, endorsement or certification by anyone named. NVIDIA, the NVIDIA logo, NVIDIA Cosmos, NVIDIA cuOpt, NVIDIA Earth-2, NVIDIA Inception, NVIDIA Isaac Sim, NVIDIA Omniverse and NVIDIA Warp are trademarks and/or registered trademarks of NVIDIA Corporation in the U.S. and other countries. Other product names belong to their owners.